Before Installing DeepStream
Make sure that you have set up the dev container prior to attempting install.
General
In order to run inference, an NVIDIA 20x series GPU or newer is required.
This will not work on macOS and ARM systems.
Installing DeepStream
There are two ways to install DeepStream.
- With the DeepStream dev container
- Through an installation script
DeepStream Dev Container
The easiest method is to switch to the DeepStream dev container, vtautoboat/development_image_deepstream. See how to change your your dev container variant.
DeepStream Installation Script
Inside the dev container, make sure your current working directory is /home/ws/.
Execute this script to start the installation.
bash .devcontainer/old_devcontainer_variant_setup_scripts/install_deepstream_yolo_dev_container.sh
This installation can take a long time.
Connecting the Camera
Running without camera
If you do not want to run with the camera, or do not have it, run
export CAMERA=false
In order to run the object detection module, the camera must be connected and forwarded to WSL
To forward the camera device to WSL, follow these instructions
Making sure the camera is seen in WSL
To verify the connection, run this command in the dev container
v4l2-ctl --list-devices
A properly connected camera will have an output similar to this (the numbers may be different)
autoboat_user@docker-desktop:/home/ws$ v4l2-ctl --list-devices
Intel(R) RealSense(TM) Depth Ca (usb-0000:00:14.0-1):
        /dev/video0
        /dev/video1
        /dev/video2
        /dev/video3
        /dev/video4
        /dev/video5
        /dev/media1
        /dev/media2
Building an Engine File
Running without inference
If you want to disable inference and skip the model creation, run
export INFERENCE=false
To build an engine file, navigate to the scripts directory. This can be done without a camera connected.
cd /home/ws/scripts/
You need to know whether this model is Yolo26 or Yolo11.
Place the .pt model file in this directory.
Run the following script to build a .engine model file based on the .pt file. This will take a while. Fill in <name_of_pt_file> without the file extension. For example, if your model is named yolo26s.pt, you should enter yolo26s.
# Build an engine file
bash build_engine_file_yolo.sh <yolo_version> <name_of_pt_file>

# For example with model file named yolo26s.pt
bash build_engine_file_yolo.sh 26 yolo26s

# For example with model file named yolo11n.pt
bash build_engine_file_yolo.sh 11 yolo11n
You will see a couple warnings similar to shown below. Those are normal.
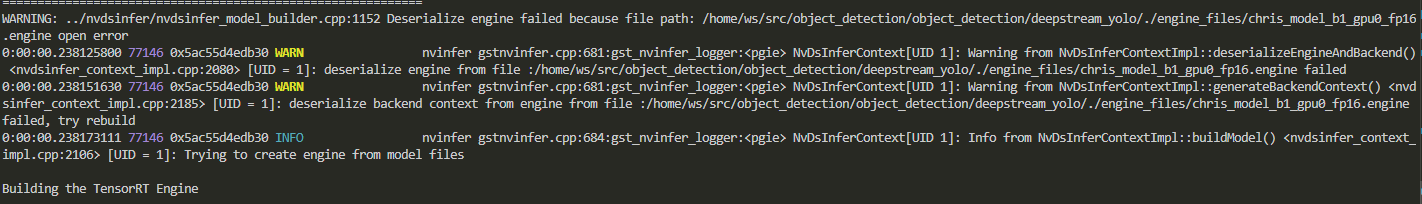
After running the script, the file will be moved to the ros_pacakges/object_detection/object_detection/config/yolo<ver>/pt_files/ directory. The script will look for files in both the scripts/ directory and pt_files/ directory, if it exists.
Running the Object Detection Module
After a model file has been created, you can run the ROS2 object detection module.
ros2 run object_detection object_detection
If you disabled the camera, the video feed will be static.
For more information and dynamically changing parameters, see the Object Detection Node.